TwinWorks
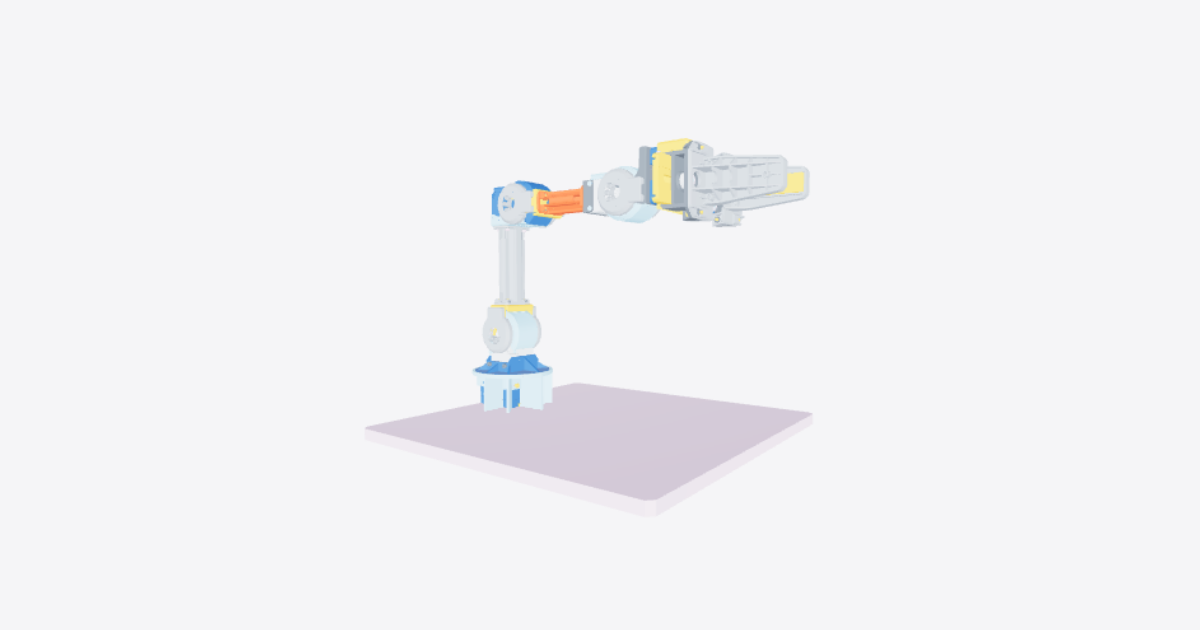
SO-101 – 3D model preview

SO-101

Téa · Robotics · 3D model · Updated 27 Oct 2026

Open in 3D

  • Procedures7shared publicly
  • Views179all time
  • Rating–No ratings yet
  • Likes0from the Community

0 comments

Procedures

Replacing servomotor 3

Maintenance · 12 steps · No ratings yet

Tools

  • Phillips-head screwdriver
12 steps
  1. Disconnect servomotor 3

    Disconnect the two cables from servomotor 3: the connection from servomotor 2 and the connection to servomotor 4.

  2. Remove arm screws — set B

    Unscrew and remove the four set B screws highlighted on the removable half of the second arm at servomotor 3. Use a Phillips-head screwdriver.

  3. Remove arm screws — set A

    Unscrew and remove the four set A screws highlighted on the removable half of the second arm at servomotor 3. Use a Phillips-head screwdriver.

  4. Detach the upper assembly

    Detach the highlighted upper assembly from servomotor 3 and set it aside as one unit. Keep the arm half, wrist, servomotors and jaws together.

  5. Unscrew servomotor 3 from the arm

    Unscrew and remove the four motor mounting screws securing servomotor 3 in the arm. Use a Phillips-head screwdriver.

  6. Remove the old servomotor

    Remove the old servomotor 3 from the arm.

  7. Install the replacement servomotor

    Place the replacement servomotor 3 in the arm in the position shown.

  8. Secure servomotor 3

    Reinstall the four motor mounting screws securing servomotor 3 in the arm. Use a Phillips-head screwdriver.

  9. Refit the upper assembly

    Refit the highlighted upper assembly onto servomotor 3 as one unit, keeping the arm half, wrist, servomotors and jaws together.

  10. Install arm screws — set A

    Reinstall the four set A screws highlighted on the removable half of the second arm at servomotor 3. Use a Phillips-head screwdriver.

  11. Install arm screws — set B

    Reinstall the four set B screws highlighted on the removable half of the second arm at servomotor 3. Use a Phillips-head screwdriver.

  12. Reconnect servomotor 3

    Reconnect the cable from servomotor 2 to servomotor 3. Reconnect the cable to servomotor 4 at servomotor 3.
Replacing servomotor 6

Maintenance · 9 steps · No ratings yet

9 steps
  1. Unscrew the Initial Set of Screws

    Unscrew the first set of screws to begin the disassembly process. Use a Phillips-head screwdriver.
  2. Unscrew the Remaining Screws

    Proceed to unscrew the remaining four screws. Use a Phillips-head screwdriver.
  3. Remove the Moving Jaw

    Remove the moving jaw part from the assembly.
  4. Remove the wiring on the servomotor

    Remove the wiring on the servomotor in order to be able to replace it.
  5. Replace the servomotor

    Replace the old servomotor with the new servomotor
  6. Wire the new servomotor

    Plug the wiring of the new servomotor
  7. Install the Moving Jaw

    Install the Moving Jaw on the new servomotor
  8. Screw the Moving Jaw

    Screw the Moving Jaw's first set of screws. Use a Phillips-head screwdriver.
  9. Screw the Moving Jaw

    Screw the Moving Jaw's second set of screws. Use a Phillips-head screwdriver.

Installing servomotor 6

Maintenance · 5 steps · No ratings yet

5 steps
  1. Install the servomotor

    Fit the new servomotor in place.

  2. Connect the servomotor wiring

    Plug the wiring into the new servomotor.

  3. Install the Moving Jaw

    Install the Moving Jaw on the new servomotor
  4. Fasten the Moving Jaw — first screw set

    Screw the Moving Jaw's first set of screws. Use a Phillips-head screwdriver.
  5. Fasten the Moving Jaw — second screw set

    Screw the Moving Jaw's second set of screws. Use a Phillips-head screwdriver.

XR

Usage · 1 step · No ratings yet

1 step
  1. Tracking the upper jaw

Assembly

Assembly · 44 steps · No ratings yet

44 steps
  1. Put the Base in place

    Put the Base of the SO101 in place in order to assemble other parts on it
  2. Put in place the first servomotor

    Put in place the first servomotor as shown.
  3. Screw the servomotor in the Base

    Screw the servomotor in the Base by screwing the 4 highlighted screws as shown.
  4. Put in the servomotor cover in place

  5. Screw the cover of the servomotor

    Screw the cover of the servomotor in order not to move
  6. Put in place the rotation pitch part

    Put in place the rotation pitch part on the servomotor
  7. Screw the Rotation Pitch

    Screw the Rotation Pitch to the servomotor using the upper side screws
  8. Screw the Rotation Pitch

    Screw the Rotation Pitch to the servomotor using the lower side screws
  9. Assemble the cover of the Rotation Pitch

  10. Put in place the second servomotor

  11. Screw the second servomotor

    Screw the second servomotor in the Rotation Pitch
  12. Assemble the arm

    Assemble the arm on the second servomotor
  13. Screw the first set of screws

  14. Screw the second set of screws

  15. Put in place the third servomotor

  16. Screw the third servomotor

    Screw the third servomotor in the arm
  17. Assemble the second arm

  18. Screw the first set of screws

    Screw the arm to the servomotor using the first set of screws
  19. Screw the second set of screws

    Screw the arm to the servomotor using the first set of screws
  20. Assemble the part as shown

    Assemble the part on the arm as shown
  21. Put in place the fourth servomotor

  22. Screw the fourth servomotor

    Screw the fourth servomotor to the arm
  23. Put in place the part as shown

    Put in place the part on the servomotor as shown
  24. Screw the part as shown

    Screw the part using the screws as shown
  25. Screw the part as shown

    Screw the part using the screws as shown
  26. Put in place the fifth servomotor

  27. Add the washer

    Add the servomotor washer
  28. Screw the fifth servomotor

  29. Put in place the lower jaw

  30. Screw the jaw to the washer and servomotor

  31. Screw the jaw to the washer and servomotor

  32. Put in place the nuts

  33. Put in place the sixth servomotor

  34. Screw the sixth servomotor

  35. Put in place the upper jaw

  36. Screw the upper jaw

  37. Screw the upper jaw

  38. Assemble the PCB

  39. Plug the first servomotor to the PCB

  40. Plug the first servomotor to the second servomotor

  41. Plug the second servomotor to the third servomotor

  42. Plug the third servomotor to the fourth servomotor

  43. Plug the fourth servomotor to the fifth servomotor

  44. Plug the fifth servomotor to the sixth servomotor

Connectors and cables check

Quality Control · 12 steps · No ratings yet

12 steps
  1. Inspect First Motor Connection

    Examine the connector at the first servomotor and ensure it's securely attached. Look for any signs of wear or damage.
  2. Inspect First to Second Motor Cable

    Check the cable connecting the first and second motors. Ensure it is properly connected and undamaged.
  3. Inspect Second Motor Connection

    Ensure the connector at the second servomotor is secure and in good condition.
  4. Inspect Second to Third Motor Cable

    Check the cable connection between the second and third motors. Verify that it is secure and free of damage.
  5. Inspect Third Motor Connection

    Examine the connector at the third servomotor for security and any visible defects.
  6. Inspect Third to Fourth Motor Cable

    Examine the cable linking the third and fourth motors. Ensure the connection is tight and the cable is intact.
  7. Inspect Fourth Motor Connection

    Check the connector at the fourth servomotor. It should be properly connected with no visible damage.
  8. Inspect Fourth to Fifth Motor Cable

    Inspect the cable connecting the fourth and fifth motors. Look for secure connections and an undamaged cable.
  9. Inspect Fifth Motor Connection

    Ensure the connector at the fifth servomotor is well-attached and in good condition.
  10. Inspect Fifth to Sixth Motor Cable

    Verify the cable connection between the fifth and sixth motors. Confirm it is secure and the cable is intact.
  11. Inspect Sixth Motor Connection

    Check the connector at the sixth servomotor. It should be secure and free from defects.
  12. Inspect Servomotor Driver Connection

    Examine the connector at the servomotor driver located at the base. Ensure it is securely attached and free of any damage.

Assembly AR

Assembly · 4 steps · No ratings yet

4 steps
  1. Position the base

    Put the SO-101 base in place to begin assembling the other parts onto it.

  2. Position the first servomotor

    Position the first servomotor in the location shown.

  3. Position the highlighted part

    Place the highlighted Base_08p_v18 part in the position shown.

  4. Install the two screws

    Install the two highlighted screws in the positions shown.

Related products

  • SO 101

    Téa

    Robotics · 3D model · 6 procedures

    No ratings yet

    0 likes · 0 comments · 0 views

  • Open Manipulator

    Téa

    Robotics · 3D model · 1 procedure

    No ratings yet

    0 likes · 0 comments · 0 views

  • OpenArm

    Téa

    Robotics · 3D model · 7 procedures

    No ratings yet

    1 like · 0 comments · 15 views

  • Robo Dog

    Omar ElSamalouty

    Robotics · 3D model · 2 procedures

    No ratings yet

    2 likes · 0 comments · 7 views